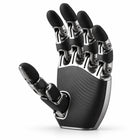
- 22 Degrees of Freedom Five in the thumb, four in each of the index, middle and ring fingers, and five in the little finger, including a new roll axis.
- Every Joint Motor-Driven All 22 joints are driven and backdrivable, each with dual encoders.
- Impact Protection on All 22 Joints A protection structure shields the gears when a joint takes an extreme external impact.
- Human-Hand Scale at 620 g An aluminium-alloy hand measuring 102 × 187 × 26 mm that holds 1 kg continuously and 2 kg at peak.
- 1,000 Hz Control Loop Over Gigabit Ethernet or USB, with position, velocity, torque, stiffness and damping commands for each joint.
- Wide 15–65 V Input Power arrives through an XT30 connector, with a 200 W peak draw.

Description
The Unitree Dex5-S is a dexterous robot hand built at 1:1 human-hand scale, with 22 degrees of freedom: five in the thumb, four each in the index, middle and ring fingers, and five in the little finger, which gains a roll axis. Each of the 22 joints has its own motor, and every one is backdrivable, with dual encoders.
That full actuation is what separates it from Unitree's Dex5-1, which has 20 degrees of freedom, 16 of them active. On the Dex5-S all 22 are driven, so each joint can be commanded in position, velocity, torque, stiffness or damping, and reports its mode, position, velocity, torque, temperature, voltage and current back to your controller.
The joints run on precision micro gearboxes, and every one has an impact-protection structure that shields the gears when the joint motor takes an extreme external blow. The hand weighs 620 g in an aluminium-alloy housing measuring 102 × 187 × 26 mm, and holds 1 kg continuously and 2 kg at peak. It runs from a 15–65 V supply through an XT30 connector, with 200 W peak power.
Connection is by Gigabit Ethernet (1000BASE-T1), USB or high-speed RS-485. Ethernet and USB run the control loop at 1,000 Hz and RS-485 at 50 Hz; in the Ethernet configuration a palm camera can plug straight into the hand. This is the Dex5-S without tactile sensing — the Dex5-S Pro adds it. Left or right hand, interface configuration and mounting to your robot are confirmed at quote.
Key Capabilities
- 22 Degrees of Freedom: Five in the thumb, four in each of the index, middle and ring fingers, and five in the little finger, including a new roll axis.
- Every Joint Motor-Driven: All 22 joints are driven and backdrivable, each with dual encoders.
- Impact Protection on All 22 Joints: A protection structure shields the gears when a joint takes an extreme external impact.
- Human-Hand Scale at 620 g: An aluminium-alloy hand measuring 102 × 187 × 26 mm that holds 1 kg continuously and 2 kg at peak.
- 1,000 Hz Control Loop: Over Gigabit Ethernet or USB, with position, velocity, torque, stiffness and damping commands for each joint.
- Wide 15–65 V Input: Power arrives through an XT30 connector, with a 200 W peak draw.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the full manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Unitree Robotics |
|---|---|
| Model | Dex5-S |
| Product Type | Dexterous robot hand |
| Scale | 1:1 human hand |
| Degrees of Freedom | 22 |
| Thumb DoF | 5 |
| Index / Middle / Ring Finger DoF | 4 each |
| Little Finger DoF | 5 (includes a roll axis) |
| Actuation | All 22 joints motor-driven and backdrivable |
| Encoders | Dual encoder |
| Impact Protection | All 22 DoF |
| Payload (continuous) | 1 kg per hand |
| Peak Payload | 2 kg |
| Dimensions (L × W × H) | 102 × 187 × 26 mm |
| Weight | 620 g |
| Housing Material | Aluminium alloy |
| Tactile Sensing | Not fitted (available on the Dex5-S Pro) |
| Supply Voltage | 15–65 V |
| Power Connector | XT30 |
| Peak Power | 200 W |
| Communication | T1s Ethernet × 2, high-speed RS-485 × 1, USB × 1 |
| Gigabit Ethernet | Yes (1000BASE-T1 configuration) |
| Baud Rate | 6 Mbps |
| Control Loop Rate | 1000 Hz (Ethernet / USB), 50 Hz (high-speed RS-485) |
| Sensing and Feedback | Joint mode, position, velocity, torque, temperature, voltage and current |
| Control Commands | Joint mode, position, velocity, torque, stiffness, damping |
| Hand Side (left / right) | Confirm at quote |
| Palm Camera Included | Confirm at quote |
| Robot Mounting and Compatibility | Confirm at quote |
Industries
Frequently Asked Questions
22: five in the thumb, four each in the index, middle and ring fingers, and five in the little finger. All 22 joints are motor-driven and backdrivable.
The Dex5-1 has 20 degrees of freedom, 16 of them active. The Dex5-S drives all 22 joints, adds a roll axis on the little finger and is built to 1:1 human-hand scale at 620 g.
Not this version. Unitree's Dex5-S Pro adds tactile sensing; otherwise the two share the same 22-DoF hand, dimensions and electrical specification.
1 kg continuously and 2 kg at peak, per hand.
The Unitree Dex5-S 22-DoF Dexterous Hand is priced at £5,125 in your market.
By Gigabit Ethernet (1000BASE-T1), USB or high-speed RS-485, from a 15–65 V supply. Ethernet and USB run a 1,000 Hz control loop and RS-485 runs at 50 Hz. Hand side and mounting to a specific arm or humanoid are confirmed at quote.
Recently Viewed
You haven't viewed any products yet.